E-commerce
Volatile SKU depth makes associate-robot choreography and replenishment access as important as nominal order lines per hour.
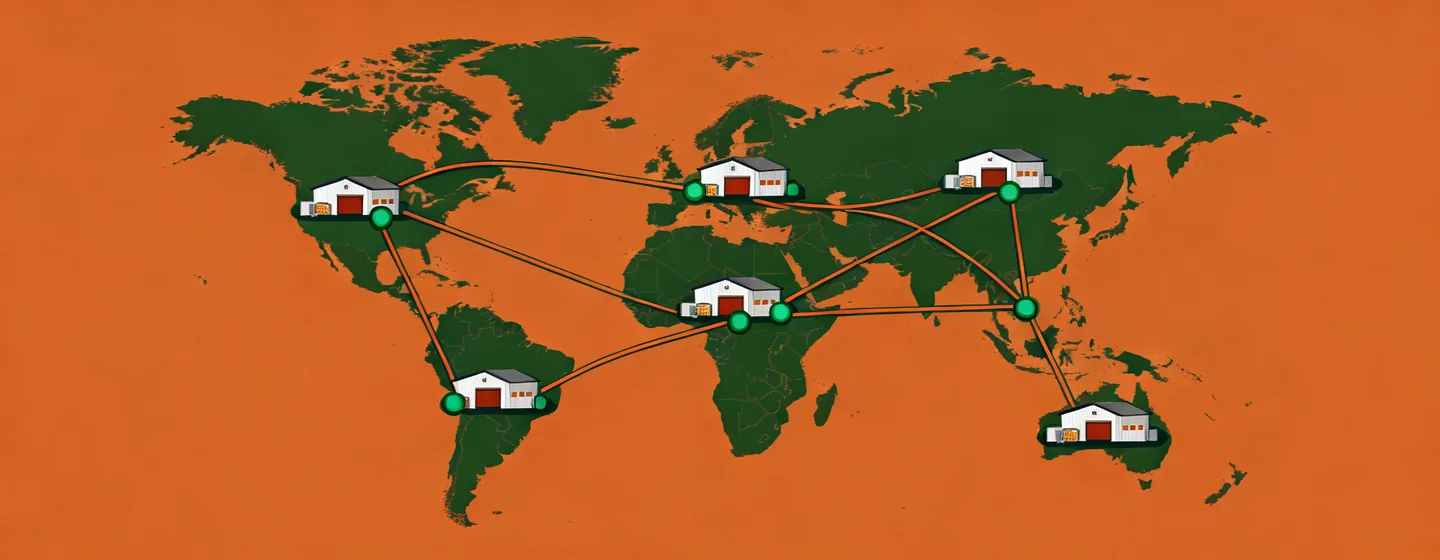
Compare how SKU depth, peak factor, temperature bands and pallet/tote mix change the fleet boundary across regions and verticals Slip Robotics supports.
North American fulfillment often pairs volatile SKU depth with aggressive peak factors. Slip Robotics designs emphasize associate-robot choreography, replenishment access and charging contention during promotional windows rather than purely average lines per hour.
Many sites keep existing racking and dock doors. Fleet concepts must respect aisle width, floor quality and temporary pedestrian routes while phased cutover protects same-day shipping promises.
European grocery networks frequently combine ambient and chilled lanes. Battery performance, condensation risk and zone transition rules become first-class design inputs alongside divert accuracy at wave release.
Projects commonly require explicit ISO 3691-4 and ISO 13849-1 planning references. Slip Robotics separates standards frameworks from model-specific certificates so RFQs stay honest.
Asia Pacific sites often trade footprint for throughput. Fleet density must still leave maintenance pull-out bays, fire access and exception parking so recovery does not collapse selectivity.
Shared buildings need client-segmented work and clear WMS ownership when missions cross tenant boundaries. Modular orchestration helps isolate failures without freezing the entire building.
Bars show relative planning intensity for Slip Robotics concept work—not measured market share. Values help teams allocate engineering effort before RFQ close.
Volatile SKU depth makes associate-robot choreography and replenishment access as important as nominal order lines per hour.
Wave departure windows and mixed case sizes require buffer discipline and clear exception disposition for damaged packs.
Sequence integrity and line-side availability depend on documented handoffs when an AMR or FMS zone is isolated.
Battery dwell, condensation and closed-door policies reshape charging strategy and human intervention paths.
Slip Robotics does not pretend every warehouse should choose AMR fleets. The useful conversation compares deterministic capacity against reconfigurable paths using the same operating-profile inputs.
Conveyors, sorters and dedicated cells often win when SKU mix is stable, peak shape is predictable and divert accuracy must stay tightly coupled to one mechanical path. The trade-off is slower layout change and heavier brownfield disruption when the network shifts.
AGV and AMR fleets often win when demand volatility, phased cutover or aisle reuse matter more than a single deterministic spine. The trade-off is stronger dependence on traffic rules, charging contention planning and interface ownership when exceptions stack during peak.
A second recurring trade-off is storage density versus direct access. Dense staging can raise cube use while reducing recovery options if exception parking and maintenance pull-out bays are omitted from the concept.
Tell us the region, temperature bands, SKU depth and peak calendar. We return the fleet questions that usually decide whether flexible robotics or fixed automation fits the work.